Badger Operated Autonomous Transport
Autonomous Surface Vessel
Problem statement
There is currently no affordable and accessible platform at UW–Madison for studying how an autonomous surface vessel can actively locate, approach, and retrieve objects under realistic conditions. These capabilities are important because autonomous vessels could eventually perform rescue, defense, and energy-industry tasks that would otherwise expose sailors, emergency responders, and industrial workers to dangerous environments. However, existing platforms do not adequately support this type of development. Metal Shark offers full scale, long-range autonomous vessels that can cost upward of $2 million, making them impractical for frequent testing and iterative student development [1] and the $4,500 BlueBoat is designed primarily for environmental surveying and data collection it does not include an active system for collecting or retrieving objects [2]. To help bridge this gap, a previous UW–Madison capstone team developed a 42-inch autonomous boat capable of navigating toward and collecting miniature buoys. Although this platform more closely represents real-world autonomous-vessel behavior, it lacks an active collection mechanism and a realistic testing environment comparable to those that could be used for rescue, debris removal, or equipment retrieval. Consequently, students and researchers cannot currently investigate how object detection, vessel positioning, collection-system operation, waves, and obstacles interact during a retrieval task. Upgrading the existing boat with an active collection system and allowing autonomous docking would give researchers and future senior design teams a reusable, lower-cost platform for testing these interactions in realistic conditions. The resulting platform would support continued development of autonomous retrieval technology while giving students experience with challenges that better reflect the needs of rescue, defense, and energy-industry applications. [1] Metal Shark Boats, “Autonomous vessels,” Metal Shark Boats. [Online]. Available: https://www.metalsharkboats.com/autonomous-vessels/Links to an external site.. [Accessed: Sep. 16, 2026]. [2] Blue Robotics, “BlueBoat – USV for hydrographic surveys and robotics,” Blue Robotics. [Online]. Available: https://bluerobotics.com/store/boat/blueboat/blueboat/Links to an external site.. [Accessed: Sep. 16, 2026].
Team members

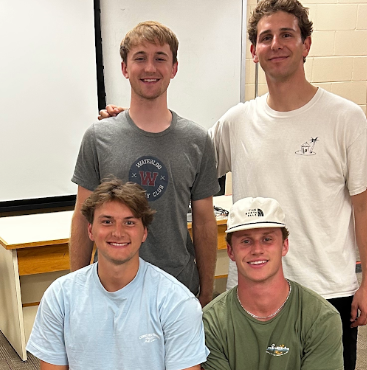
Julian Ildau-Tarmo – accountant
Jonas Price – facilitator
Joseph Venner – admin
Leonardo Losch – communicator
Client
Gabriele Librandi
Fincantieri