StabiliTail
Actuated Tail Module for Quadruped Stability on Unstructured Jobsites
Problem statement
Picture a four legged robot walking across a muddy jobsite, catching a foot in a soft patch, and tipping over with no one there to pick it up. This is a real concern for JP Cullen, the Wisconsin contractor building UW–Madison’s Kellner Center, who is testing a Unitree B2 quadruped for progress monitoring, inventory tracking, and safety inspections. Right now the B2 can only recover its balance in two ways: pushing off a planted foot or taking a step to a new one, and both of those depend on a foot finding solid ground. That is not something JP Cullen can count on with the ice, mud, and unfinished walkways that show up on a Wisconsin jobsite through the changing seasons. Because of this, the robot still needs a person walking next to it at all times, which means it cannot run the unattended shifts that would actually save the company time and keep workers out of hazardous areas. Commercial quadrupeds on the market today share this same gap, since none of them include a mechanism built specifically to stop unwanted body rotation once a foot loses its grip. Researchers have shown that a tail is especially good at correcting this kind of rotation right when a robot hits an unexpected change in terrain, and that a similar tail can actively shift its own mass to keep a robot’s body balanced the same way a cat’s or a dinosaur’s tail does. So far, though, this work has only been tested in simulation and in clean lab settings, never on the kind of unpredictable ground a real jobsite throws at a robot. Until that gap is closed, JP Cullen and contractors like them will not trust a quadruped to work on its own. We plan to design, build, and test an actuated tail module for a Unitree Go2 that closes this gap, giving contractors the confidence to send their robots out without a babysitter and cutting down on downtime, equipment damage, and the number of workers who have to step into unsafe areas just to watch a machine.
Team members

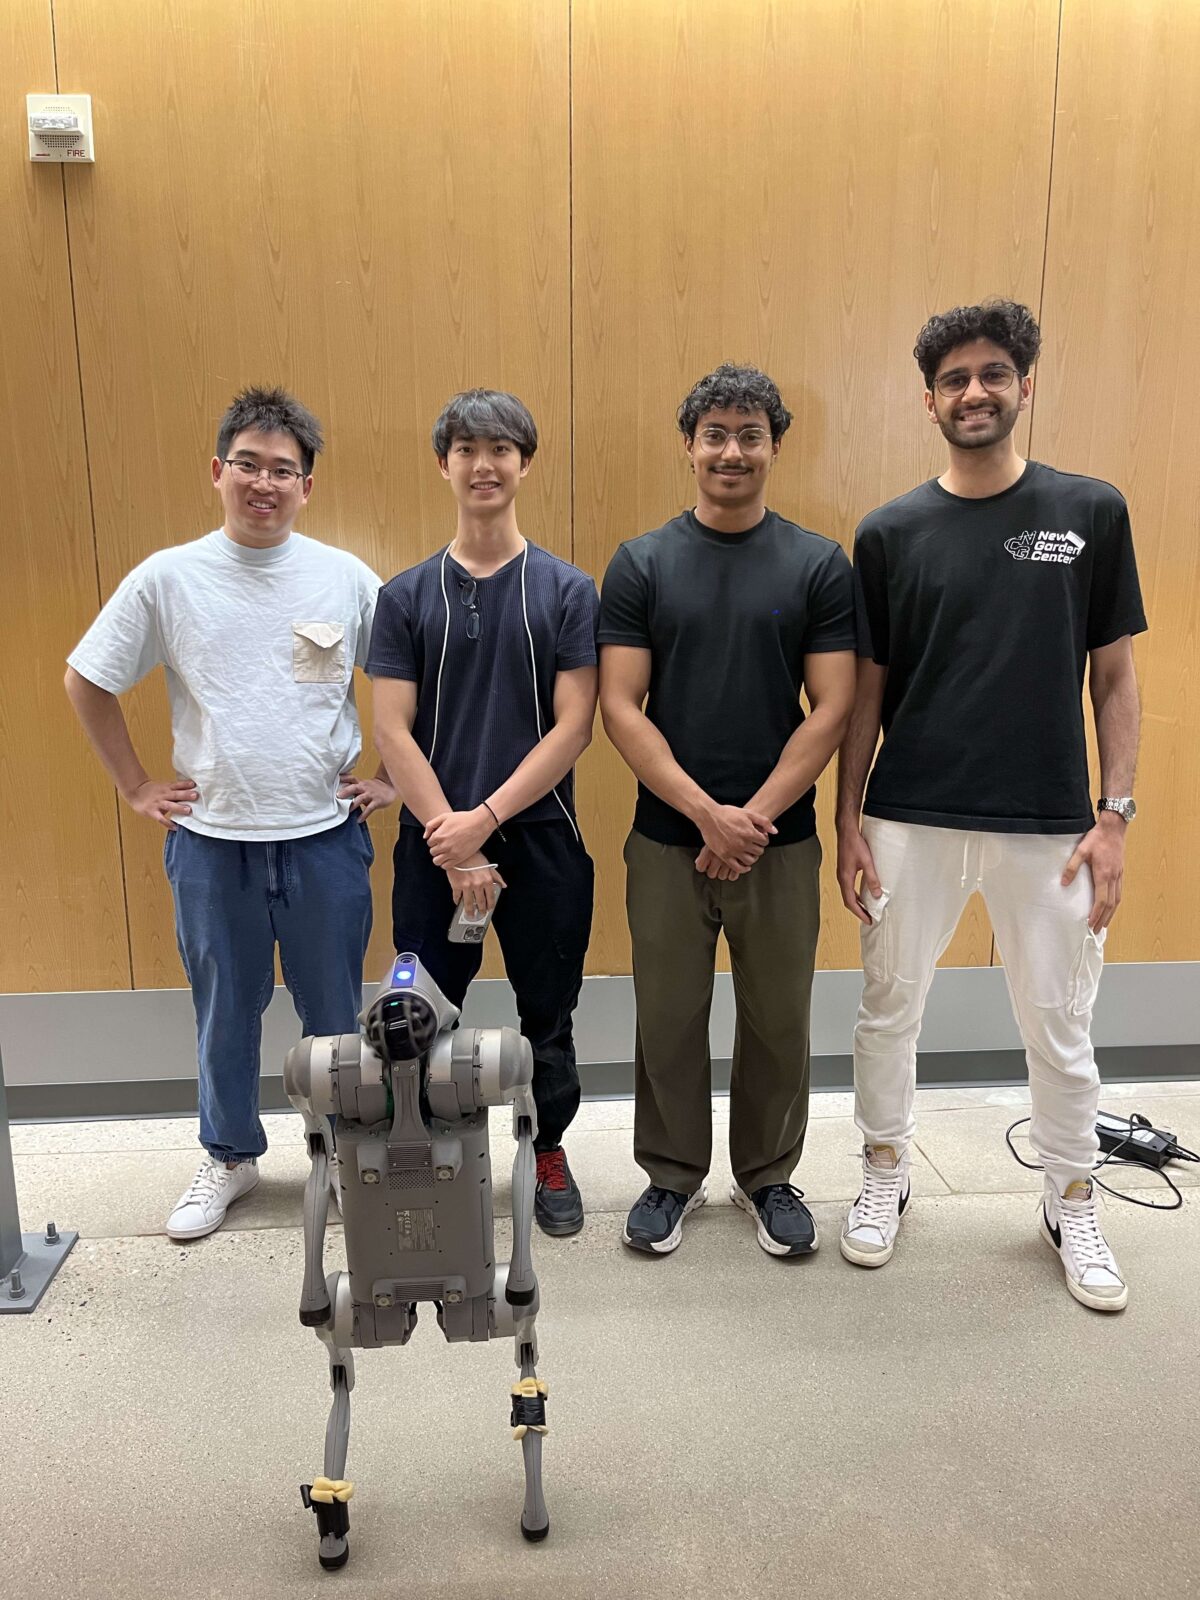
Abdulla Alhashmi – accountant
Jasir Kacem – admin
Siliang Cen – facilitator
Tund Theerawit – communicator
Client
Peter Adamczyk
UW – Mechanical Engineering