RespiRobotics
Respiratory Motion Fixture for Spine Robotics
Problem statement
Robotic and navigation-assisted spine surgery is only as safe as the anatomical models it relies on. When respiratory motion causes vertebrae to shift after registration, the resulting discrepancy between the registered image and actual anatomy presents a real risk to patient safety. With studies demonstrating mean vertebral displacements of about 2 mm, particularly in the lower thoracic spine [1], the accuracy of the robotic navigation must be validated on a moving model. While previous solutions have included using cadavers to track spinal movement, it has proven to be costly, time consuming, and is no longer feasible for new spinal robot technologies such as Medtronic’s Stealth Autopilot spine robot [2]. A physiologically representative way of testing and validating robotic surgery systems against these conditions allows engineers to create a safer and more reliable surgical robot. The solution is to develop a physiologically representative method for simulating respiratory-induced vertebral motion, enabling more realistic testing and validation of robotic spine surgery technologies. References 1. Guha D, Jakubovic R, Gupta S, Alotaibi NM, Soliman MAR, Fehlings MG, Yee A, Yang VXD. Intraoperative Error Propagation in 3D Spinal Navigation From Nonsegmental Registration: A Prospective Cadaveric and Clinical Study. Global Spine Journal. 2019;9(8):815-821. doi:10.1177/2192568218804556. 2. Elmi-Terander A, Skulason H, Söderman M, Racadio J, Homan R, Babic D, van der Vaart N, Nachabe R. Surgical Navigation Technology Based on Augmented Reality and Integrated 3D Intraoperative Imaging: A Spine Cadaveric Feasibility and Accuracy Study. Spine (Phila Pa 1976). 2016 Nov 1;41(21):E1303-E1311. doi: 10.1097/BRS.0000000000001830. PMID: 27513166; PMCID: PMC5113235.
Team members

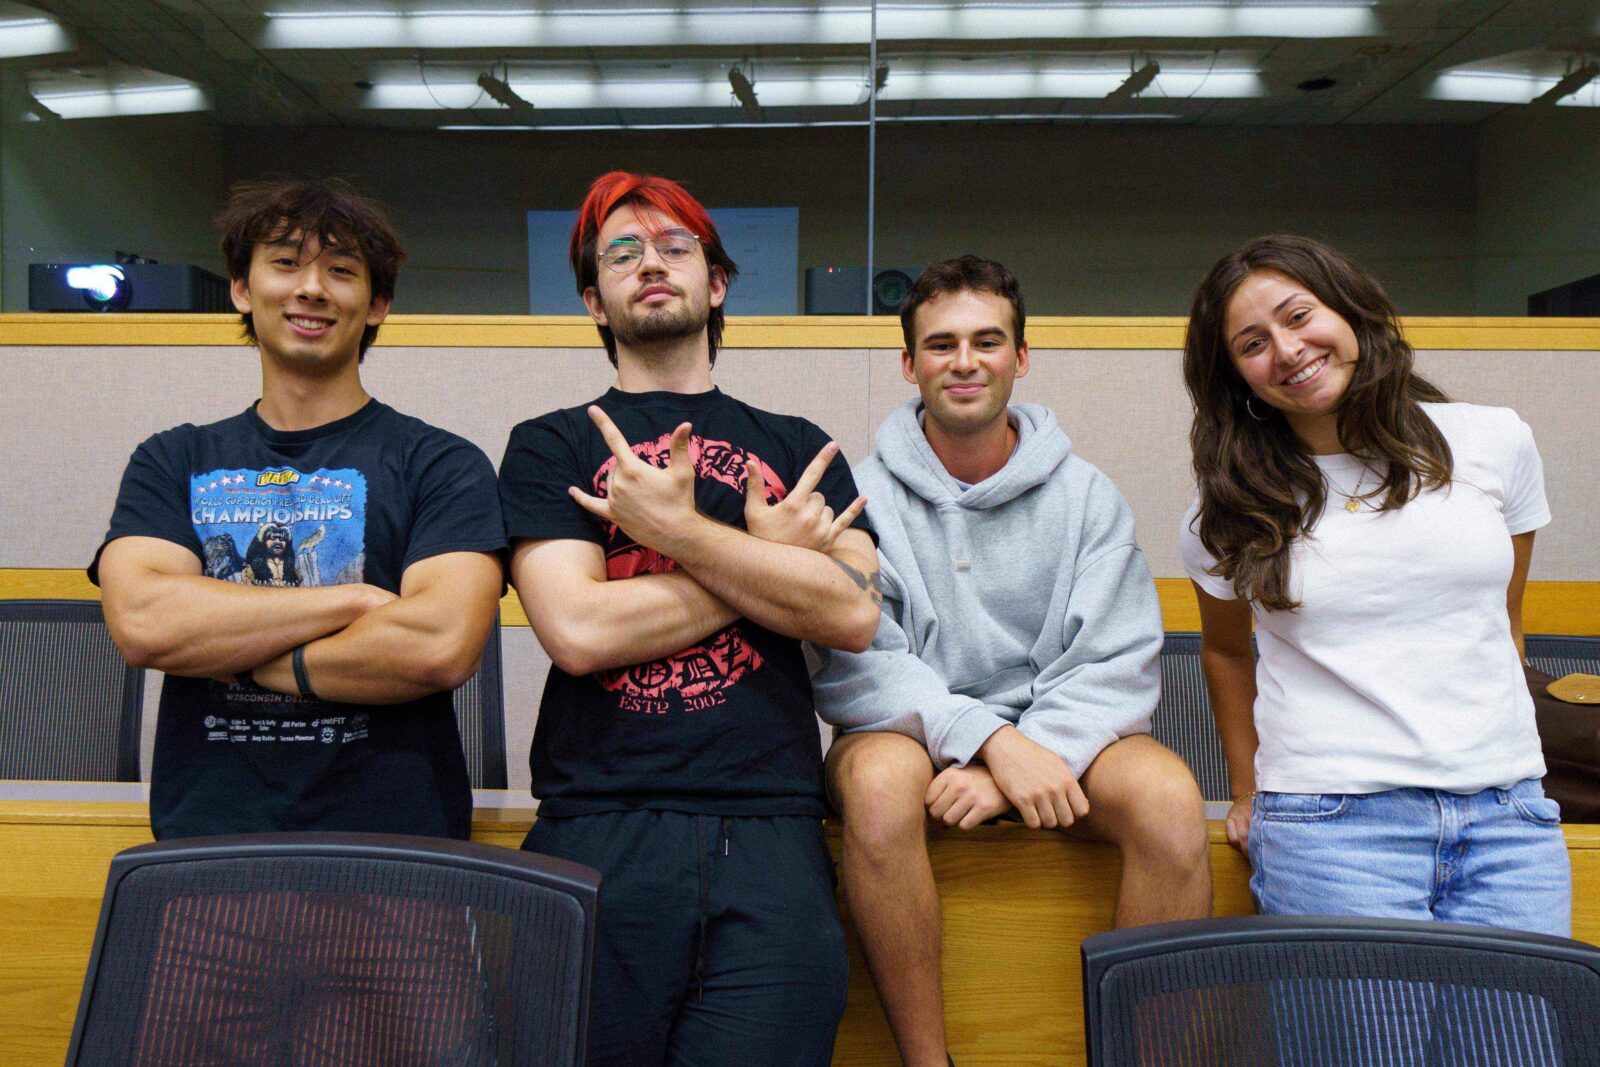
Ava Waller – communicator
Ethan Williams – accountant
Joseph Miller – facilitator
Leo Larico – admin
Client
Kate Nelson
Medtronic